F. Tokuda, A. Seino, A. Kobayashi and K. Kosuge, “CNN-based Visual Servoing for Simultaneous Positioning and Flattening of Soft Fabric Parts,” Proc. IEEE ICRA, pp. 748-754, 2023.
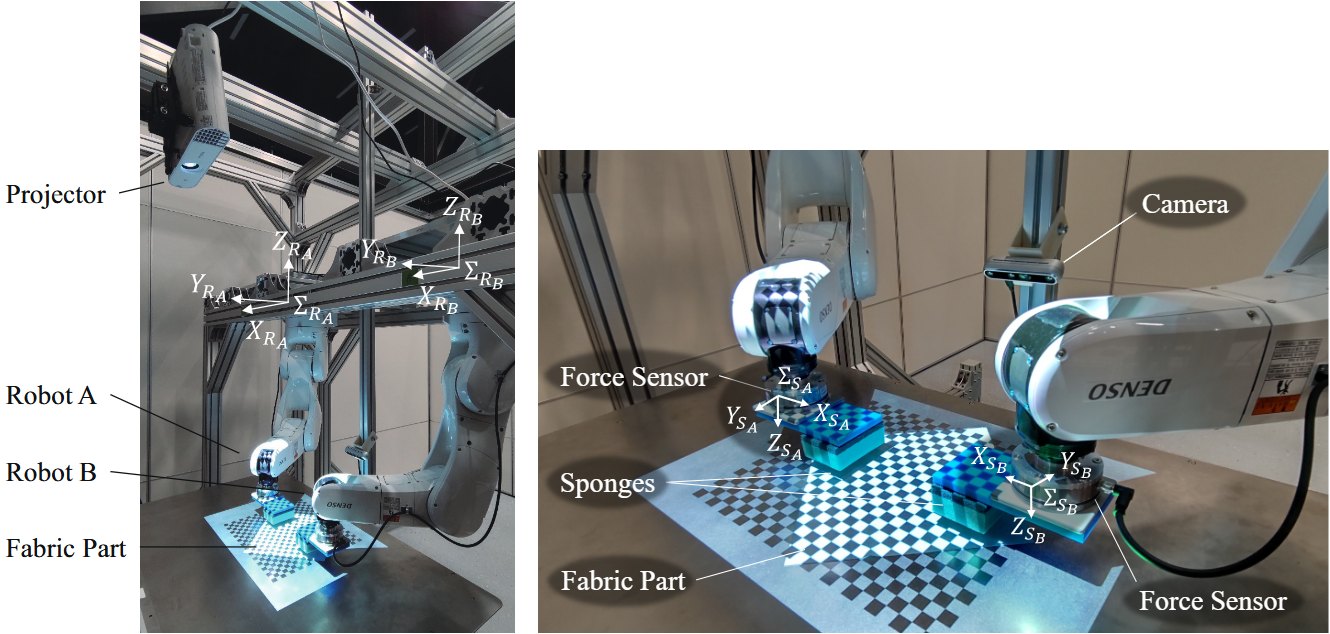
Moving a piece of fabric also changes its shape. On plain fabric, wrinkles are also hard to see in an ordinary image.
I used structured lighting to make the surface relief visible, and fed grayscale images together with force/torque measurements into a CNN that outputs dual-arm motions. The training data were collected by moving the real robot.
Real-robot experiments tested whether the robot could position and flatten fabric at the same time, including wrinkles that did not appear in the training data.