Home › Research

Research

These are my first-author projects, newest first. Papers I coauthored are listed under Publications.

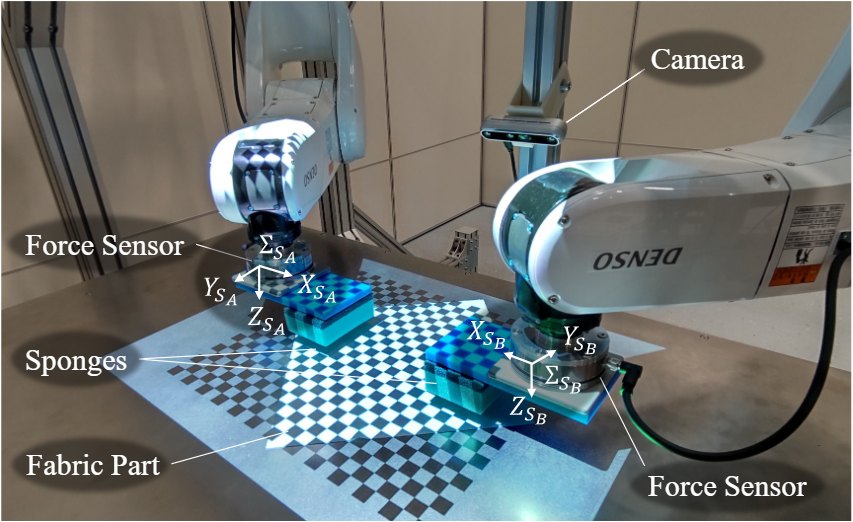
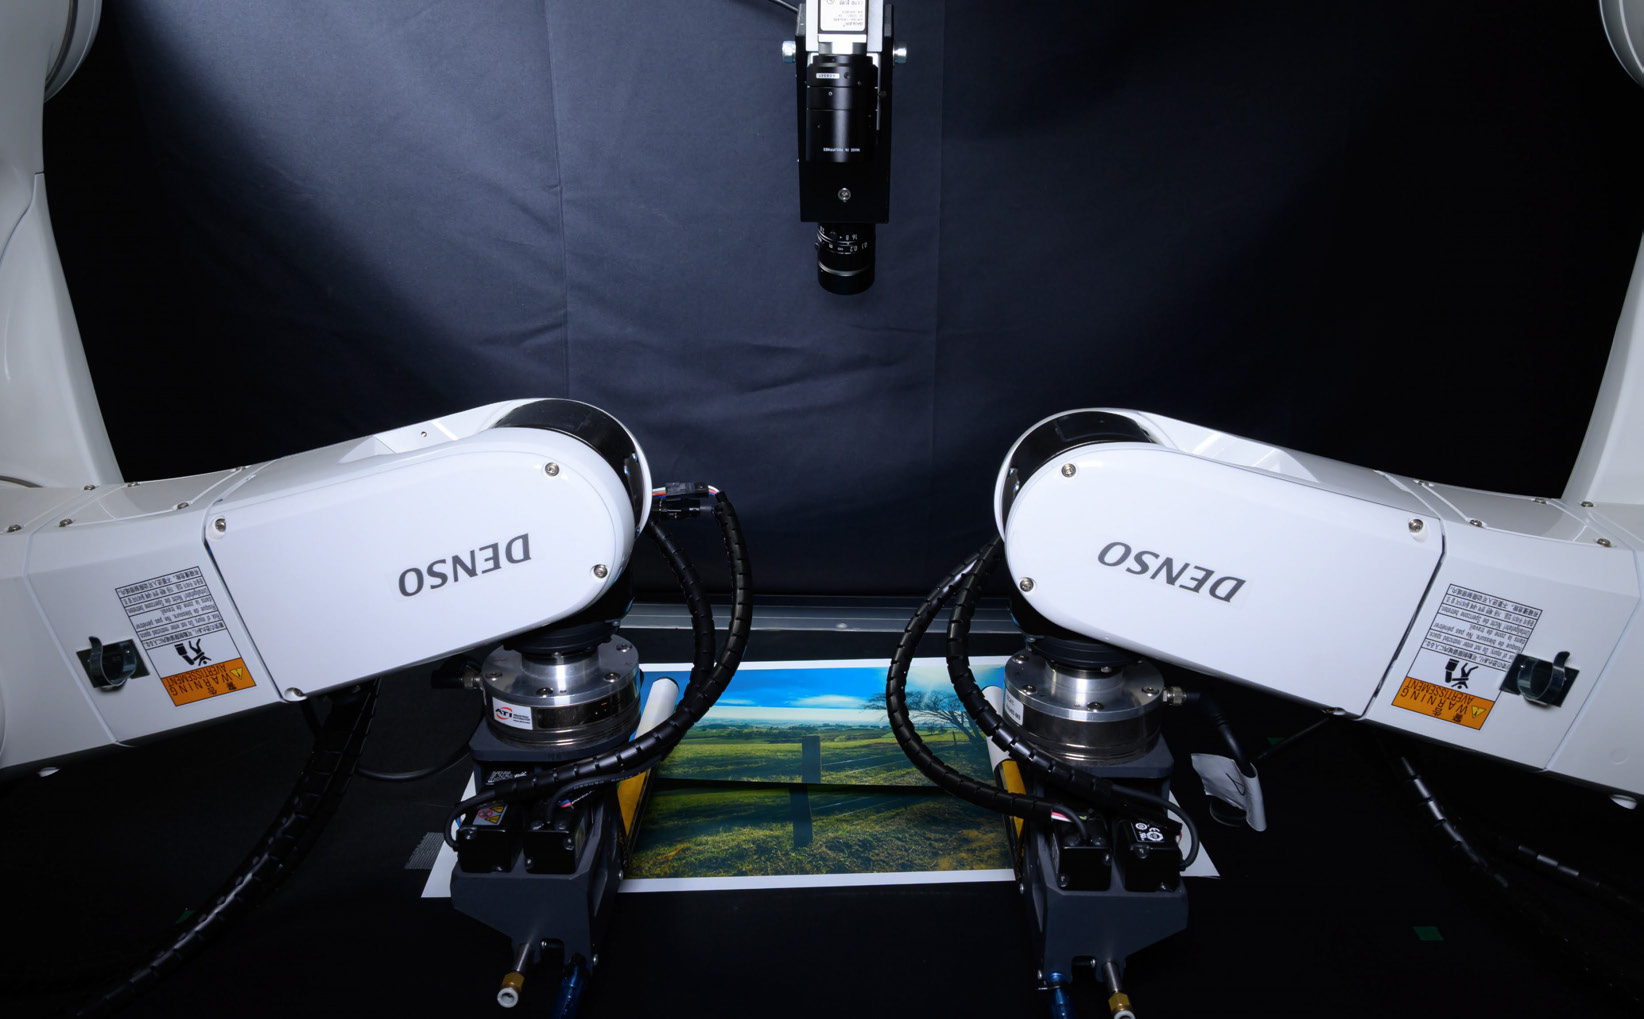
Dual-arm setup used for fabric texture matching (Fig. 1 of the author version).
RA-L 2026

Fabric texture matching with a dual-arm robot

Transformer Driven Visual Servoing for Fabric Texture Matching Using Dual-Arm Manipulator

Two patterned fabric pieces are stacked so that their patterns line up. A Transformer-based model estimates the pose offset from images, and dual-arm impedance control keeps the fabric taut during alignment and placement.
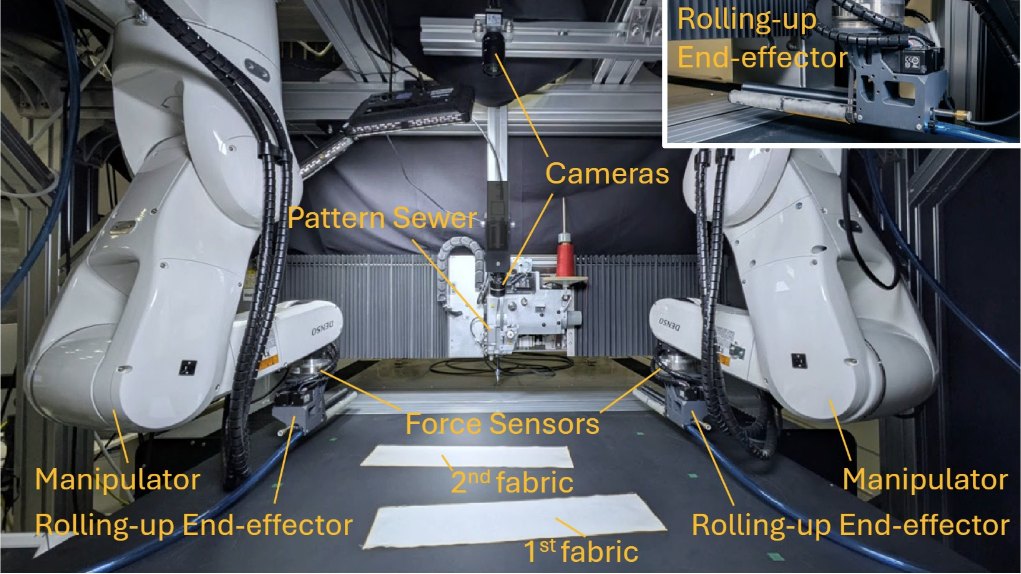
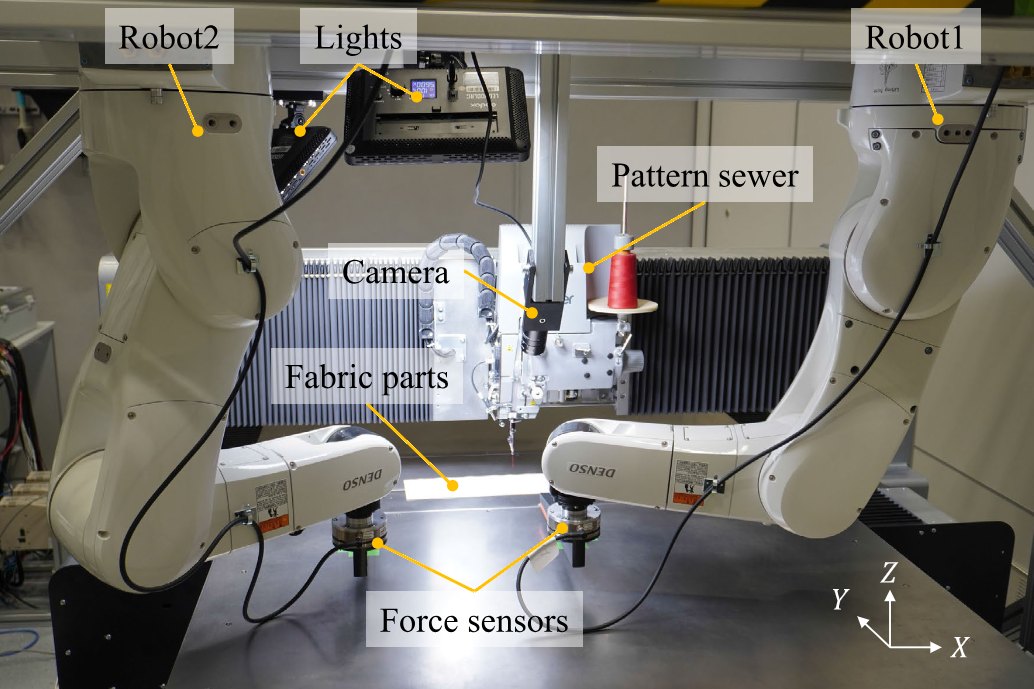
Experimental setup for fixture-free sewing: two robots, a pattern sewer, a camera, lights and force sensors.
T-ASE 2025

Fixture-free sewing with a dual-arm robot

Fixture-Free 2D Sewing Using a Dual-Arm Manipulator System

The two arms hold the fabric from both sides, adjust its tension and follow a seam line tracked by a camera. Two stacked pieces are sewn together without a fixture, including along curved seams.

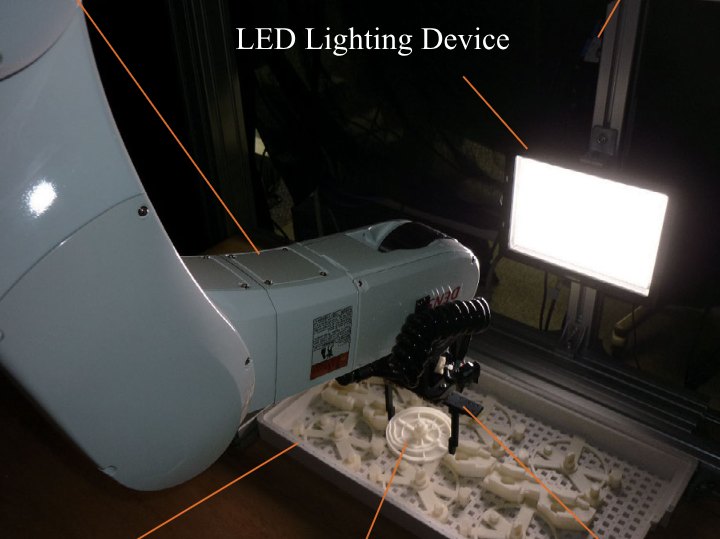
The 6-DOF manipulator, LED light, parallel gripper and alignment tray used in the positioning experiments.
Access 2021

CNN-based visual servoing for object positioning

Convolutional Neural Network-Based Visual Servoing for Eye-to-Hand Manipulator

The robot compares a target image with the current image to estimate the motion needed to reach the target pose. This was my doctoral work and uses a camera fixed outside the robot (eye-to-hand).

Current work

Learning-based methods with visual feedback

I am combining generative models and imitation learning with visual feedback to make deformable object manipulation more precise. I am also looking at how visual feedback can be built into vision-language-action (VLA) models.

Telecommunications Advancement Foundation research grant, 2026–2028

Fabric shape estimation and closed-loop control

I am working on combining mesh-based shape estimation with visual feedback control so that deformable objects can be handled more accurately.

NSK Foundation for the Advancement of Mechatronics research grant, 2026–2028