F. Tokuda, A. Seino, A. Kobayashi and K. Kosuge, “Robotic Sewing System for Fully Automated Fabric Picking, Stacking, Loading, Sewing, and Unloading,” Proc. IEEE ICMA, pp. 1124-1130, 2025.
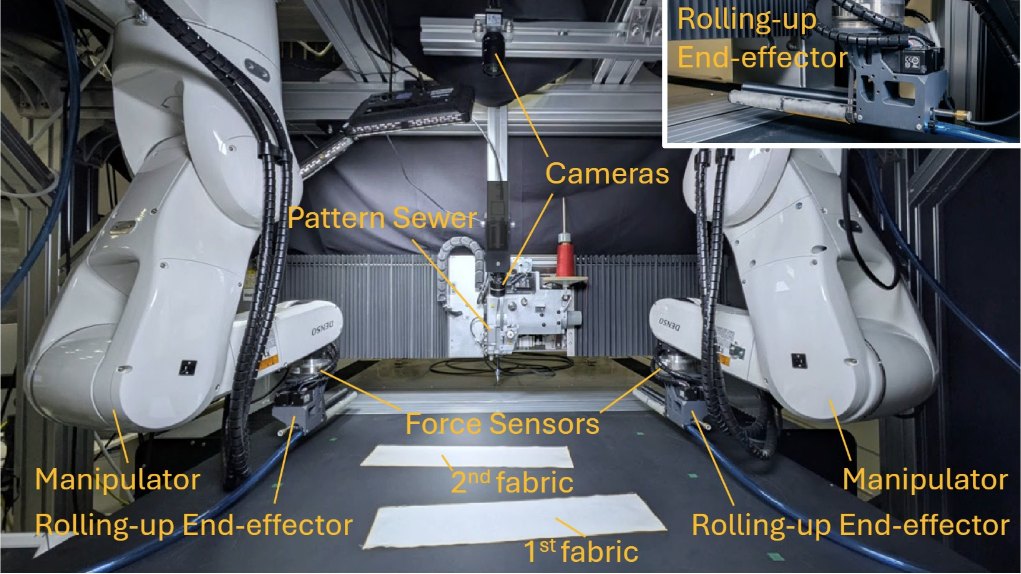
Automating the stitching alone still leaves people preparing fabric before the sewing machine and taking it away afterwards. This system runs picking, stacking, loading, sewing and unloading as one continuous process.
It consists of a dual-arm robot, rolling-up end-effectors, a sewing head, force sensors and cameras, with no dedicated fixtures, and everything is controlled from a single PC. Image segmentation and pose estimation give the fabric state, from which the sewing trajectory is computed.
Experiments on relatively thin fabrics showed the full sequence running automatically for several predefined seam shapes. The results apply to the fabrics and conditions reported in the paper.