F. Tokuda, R. Murakami, A. Seino, A. Kobayashi, M. Hayashibe and K. Kosuge, “Fixture-Free 2D Sewing Using a Dual-Arm Manipulator System,” IEEE Transactions on Automation Science and Engineering, vol. 22, pp. 7927-7940, 2025.
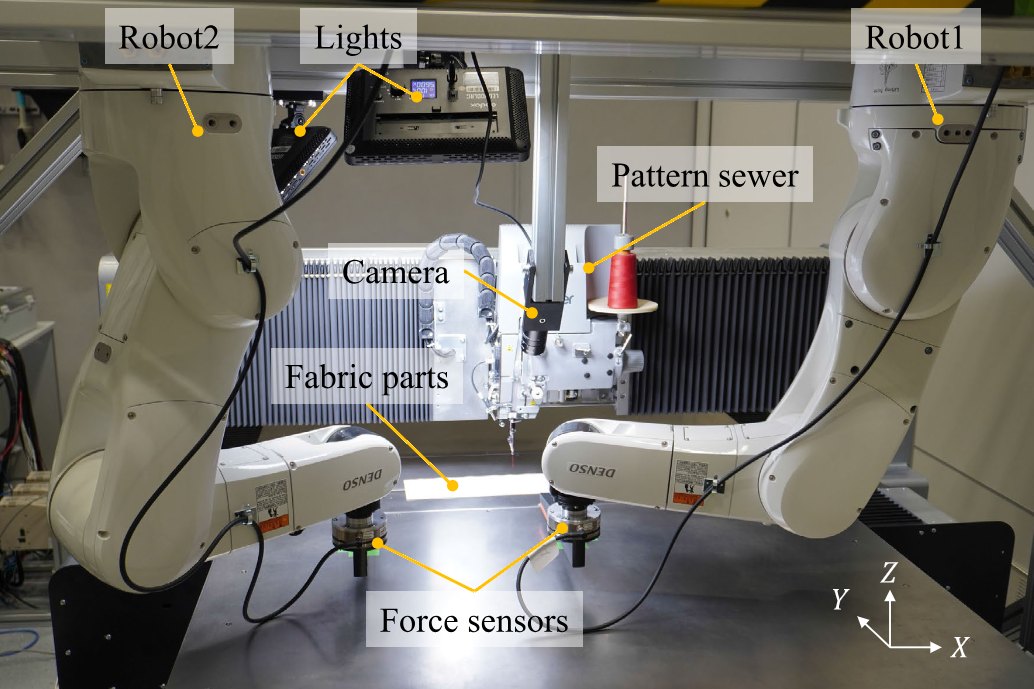
Sewing with fixtures means adjusting or remaking the fixture whenever the fabric shape or size changes. Here the robot sews without one: the two arms hold the fabric from both sides and control its tension.
A camera tracks a seam line printed on the fabric, and visual feedback moves the fabric along it. Fabric feed is coordinated with the needle stitch by stitch.
Real-robot experiments used two pre-aligned, stacked pieces with straight and curved seam lines. The later ICMA 2025 system extends the automation to the handling steps around sewing.